Active propulsion noise shaping for multi-rotor aircraft localization
Also presented at ICML 2024 Workshop (AI4Science).
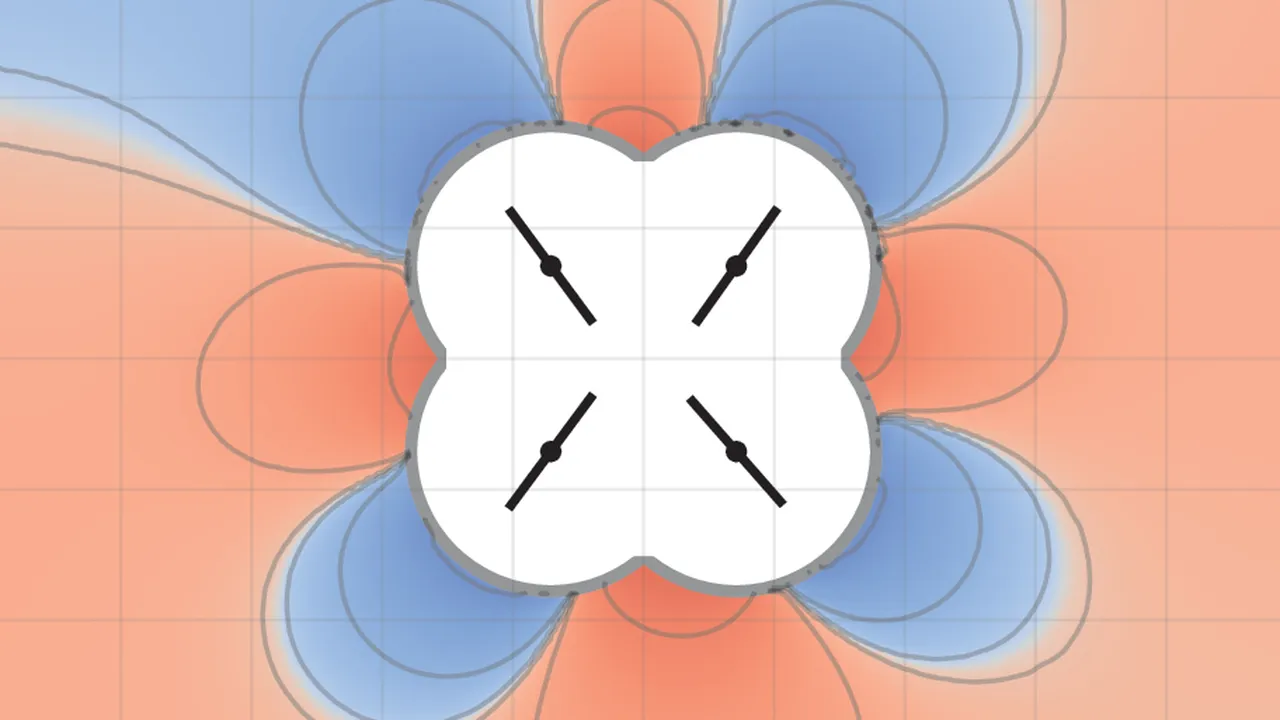
A drone that localizes itself by listening to its own rotor noise, which it learns to shape.
Key result
Learning a drone's rotor phases together with a neural localizer lets it localize itself from its own propulsion noise, more than 2.7 times better in simulation than the best handcrafted modulation.
Abstract
Multi-rotor aerial autonomous vehicles (MAVs) primarily rely on vision for navigation purposes. However, visual localization and odometry techniques suffer from poor performance in low or direct sunlight, a limited field of view, and vulnerability to occlusions. Acoustic sensing can serve as a complementary or even alternative modality for vision in many situations, and it also has the added benefits of lower system cost and energy footprint, which is especially important for micro aircraft. This paper proposes actively controlling and shaping the aircraft propulsion noise generated by the rotors to benefit localization tasks, rather than considering it a harmful nuisance. We present a neural network architecture for selfnoise-based localization in a known environment. We show that training it simultaneously with learning time-varying rotor phase modulation achieves accurate and robust localization. The proposed methods are evaluated using a computationally affordable simulation of MAV rotor noise in 2D acoustic environments that is fitted to real recordings of rotor pressure fields.
Abstract as published on arXiv.
Cite
@inproceedings{Serussi_2024,
  title={Active propulsion noise shaping for multi-rotor aircraft localization},
  url={http://dx.doi.org/10.1109/IROS58592.2024.10802115},
  DOI={10.1109/iros58592.2024.10802115},
  booktitle={2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  publisher={IEEE},
  author={Serussi, Gabriele and Shor, Tamir and Hirshberg, Tom and Baskin, Chaim and Bronstein, Alex M.},
  year={2024},
  month=oct,
  pages={472--479}
}
Topics
- drone localization
- acoustic localization
- multi-rotor aircraft
- propulsion noise
- rotor phase modulation
- robotics
* Equal contribution.